TORNADO Presents New Robotics Research Results at ADRF26 in Porto
Advancing AI-powered robotics, deformable object manipulation and human–robot interaction.
ABOUT THE EVENT
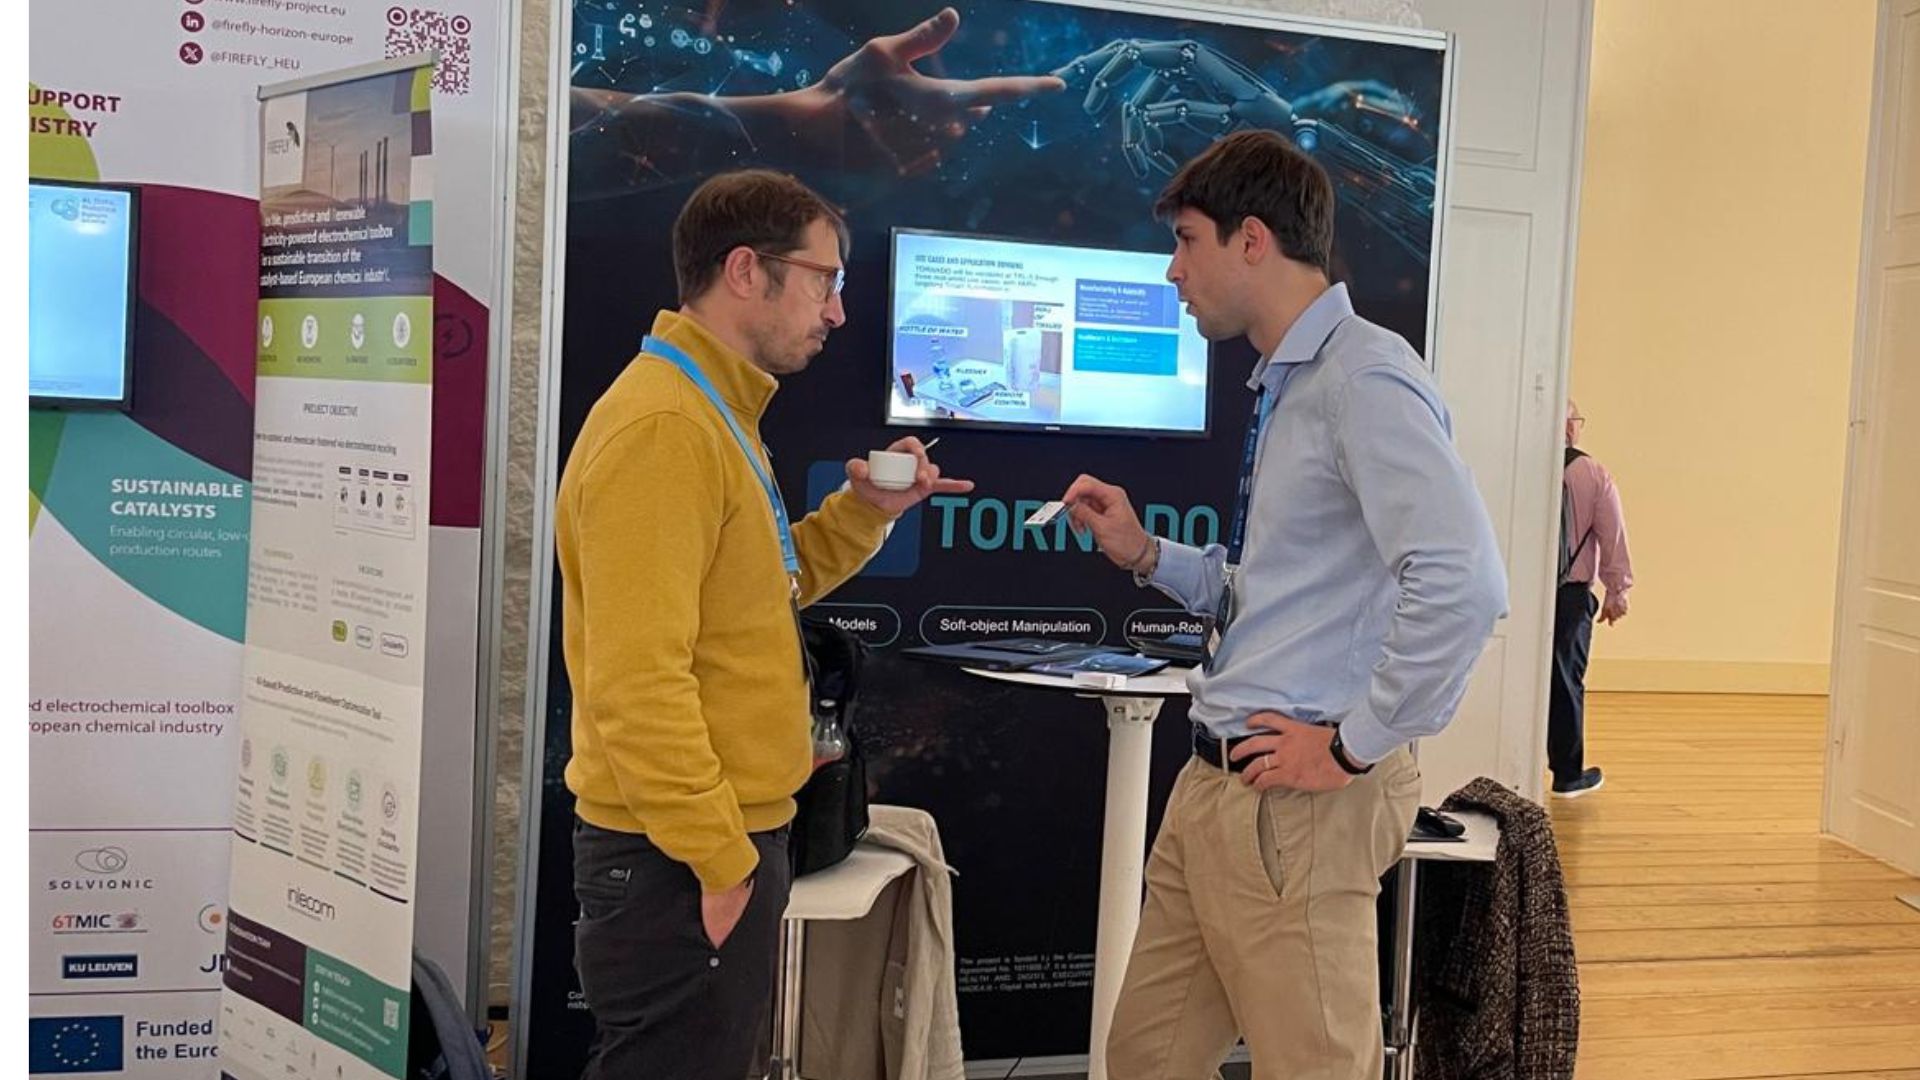
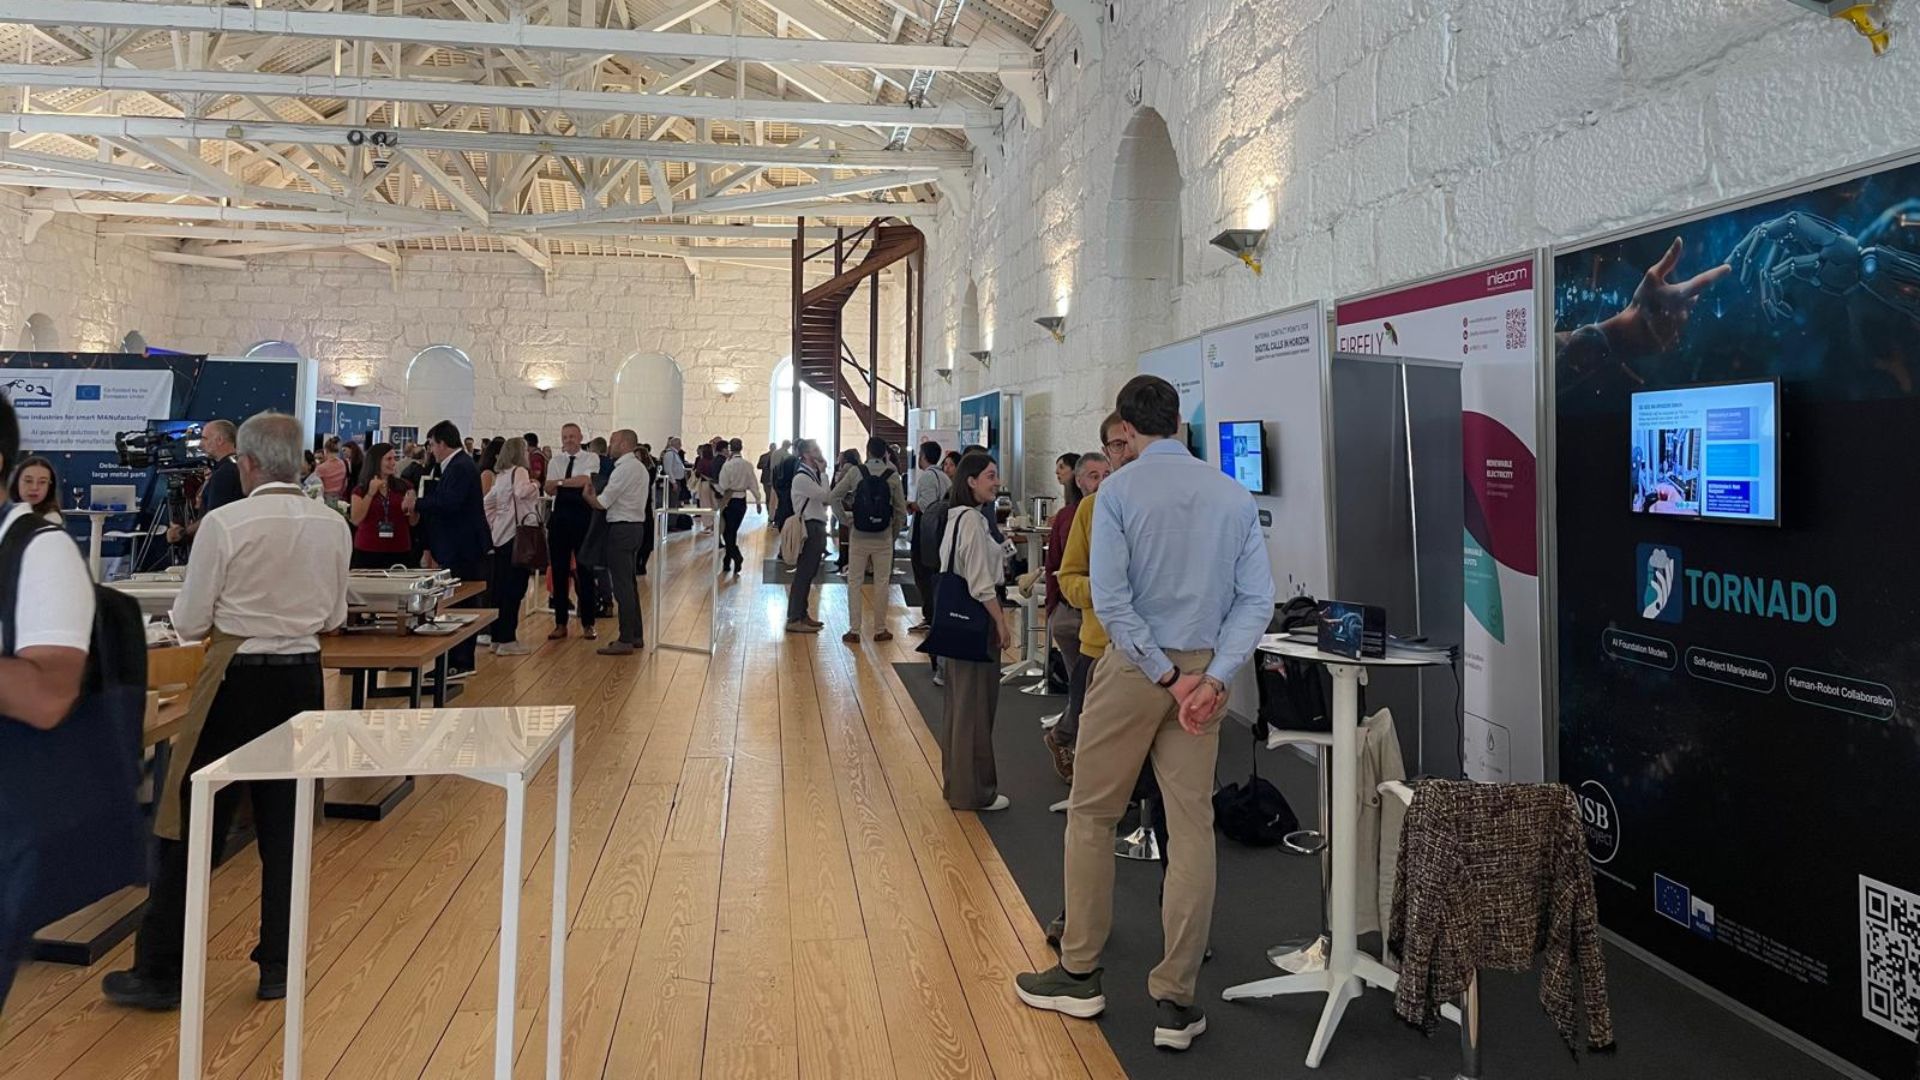
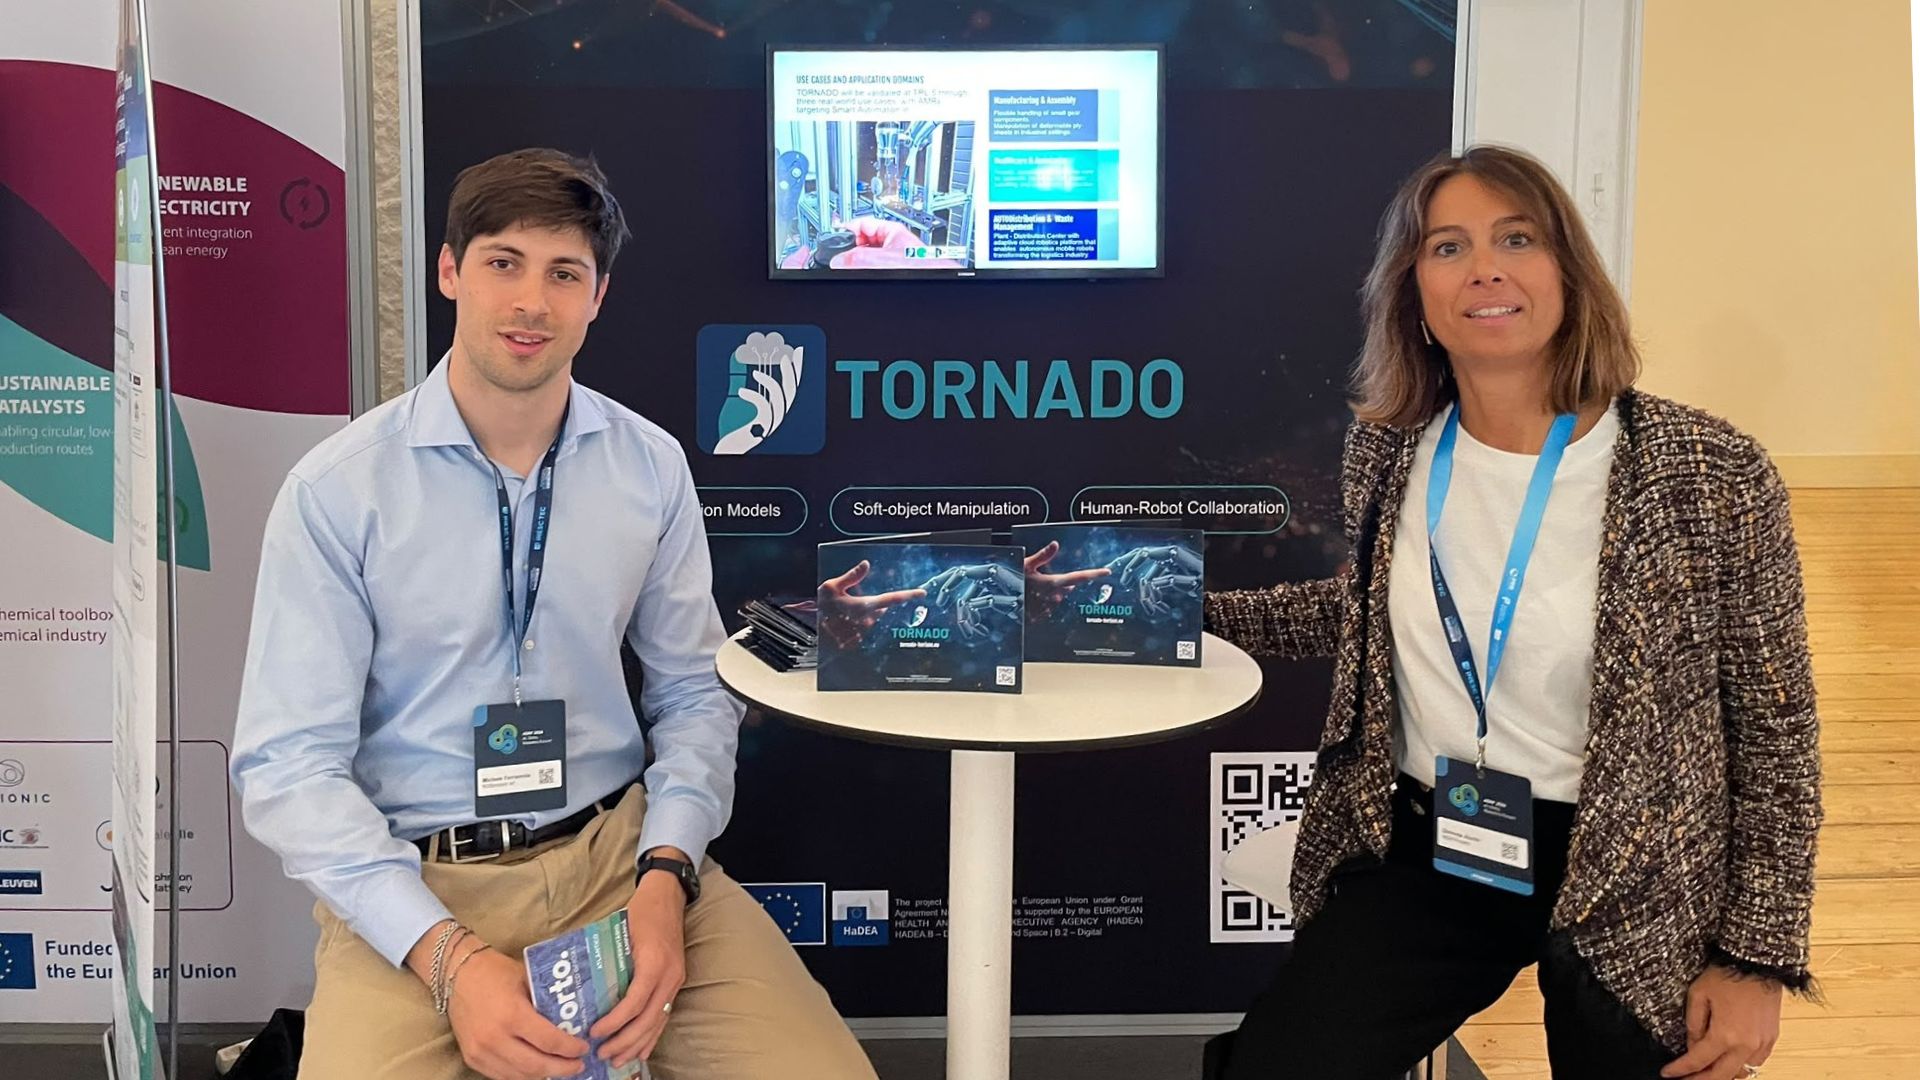
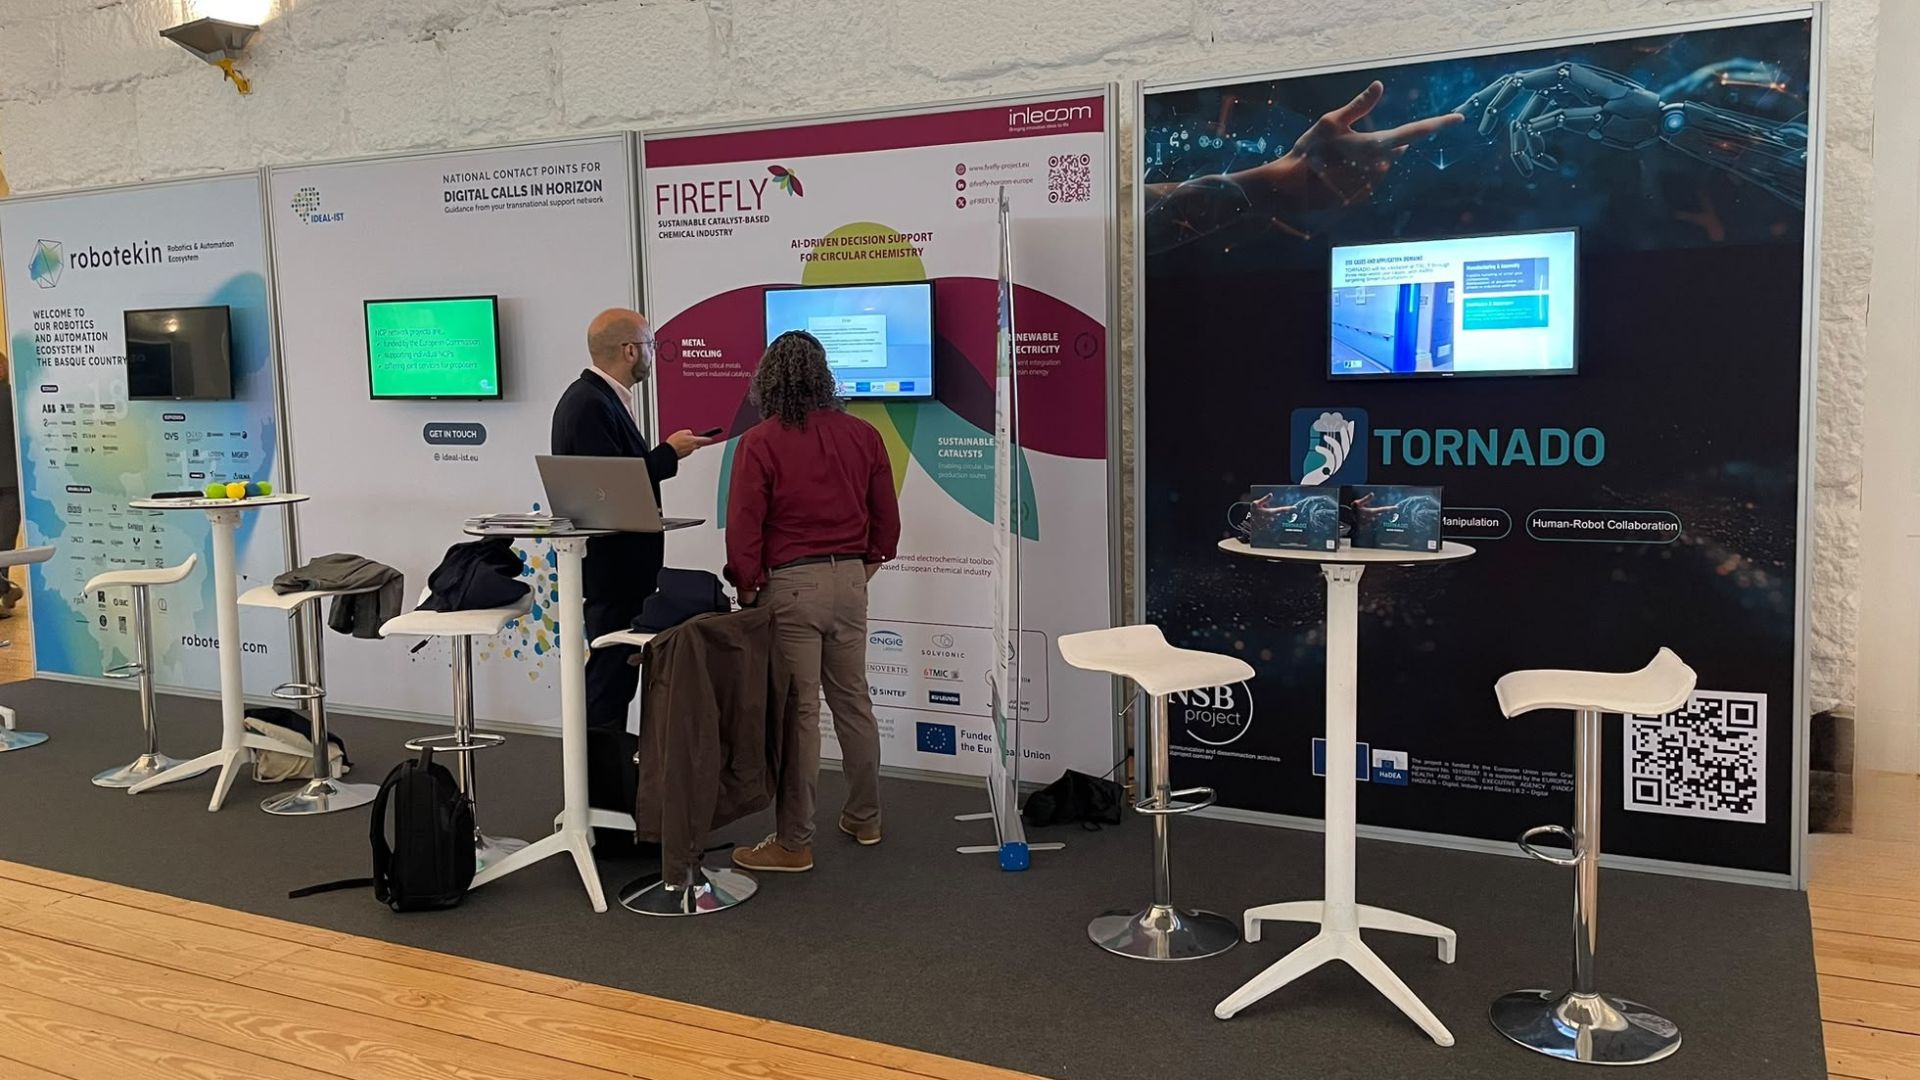
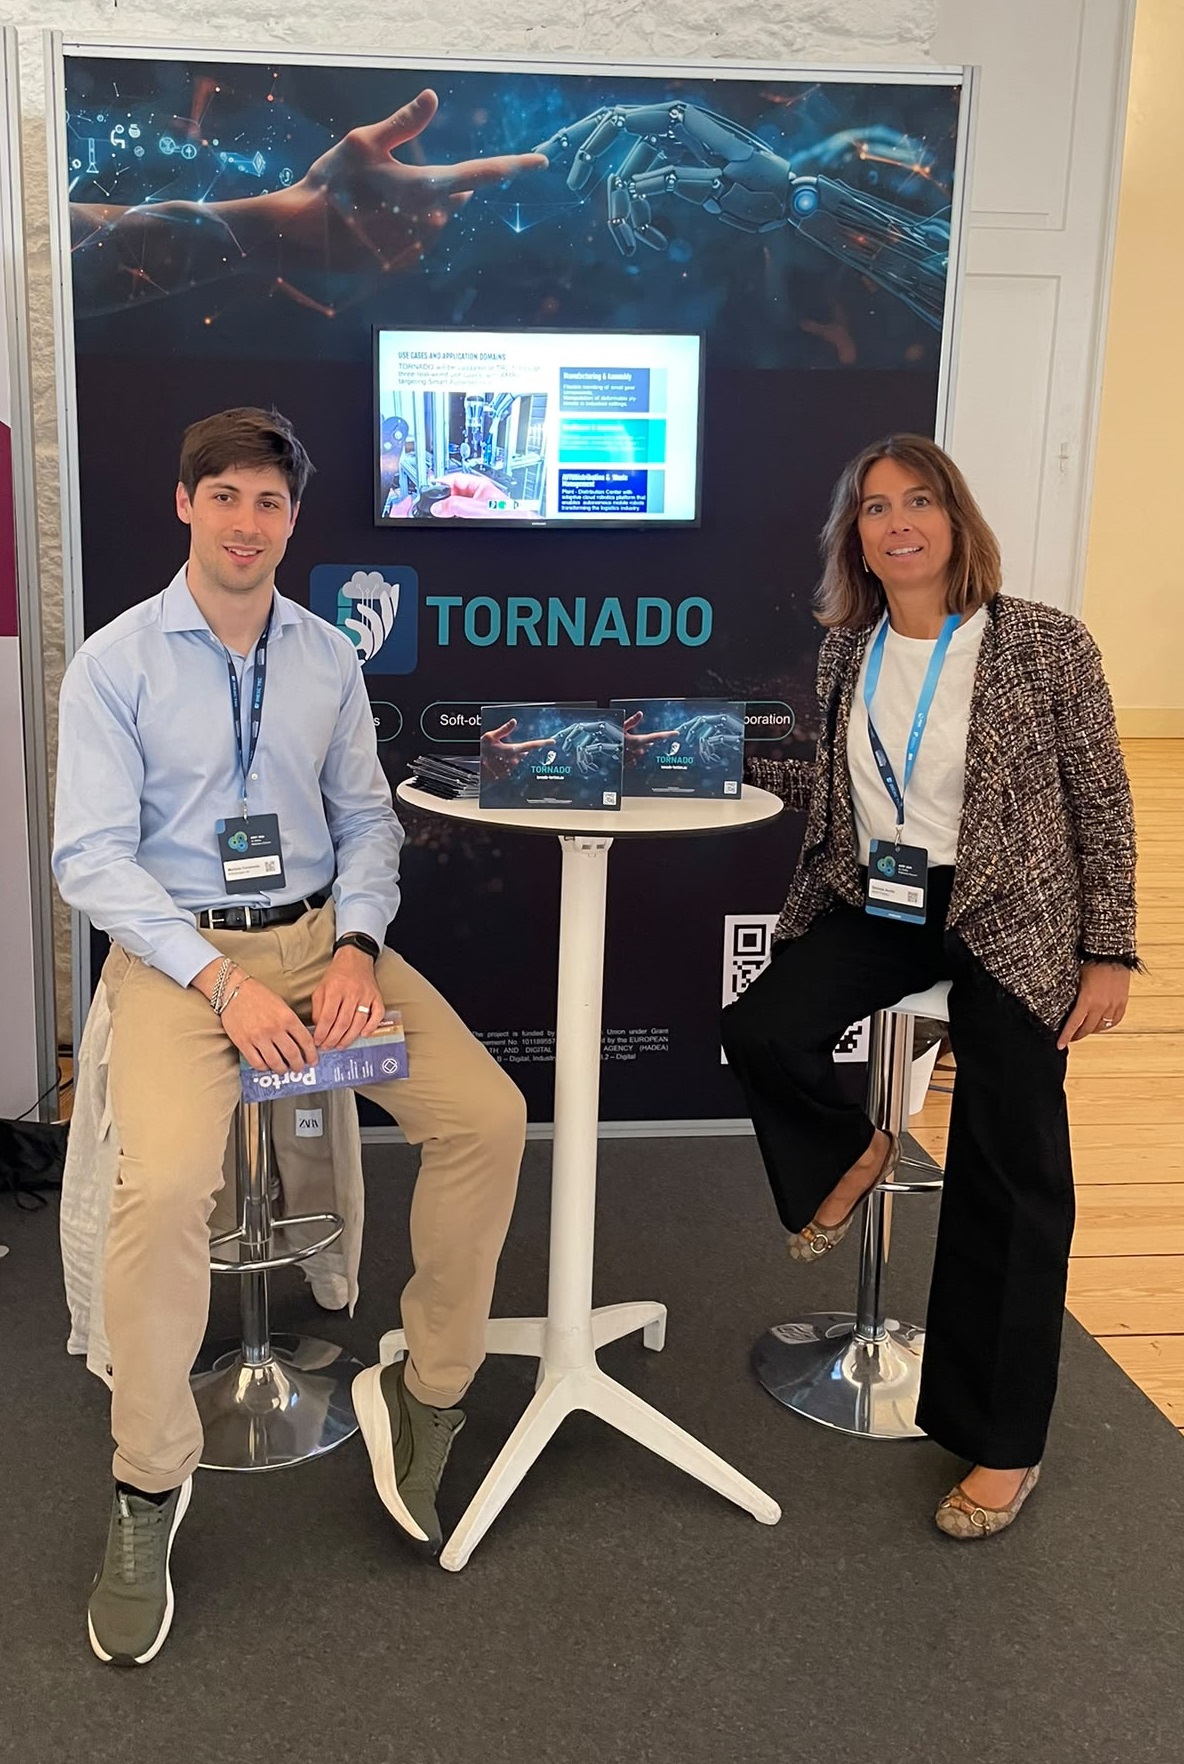
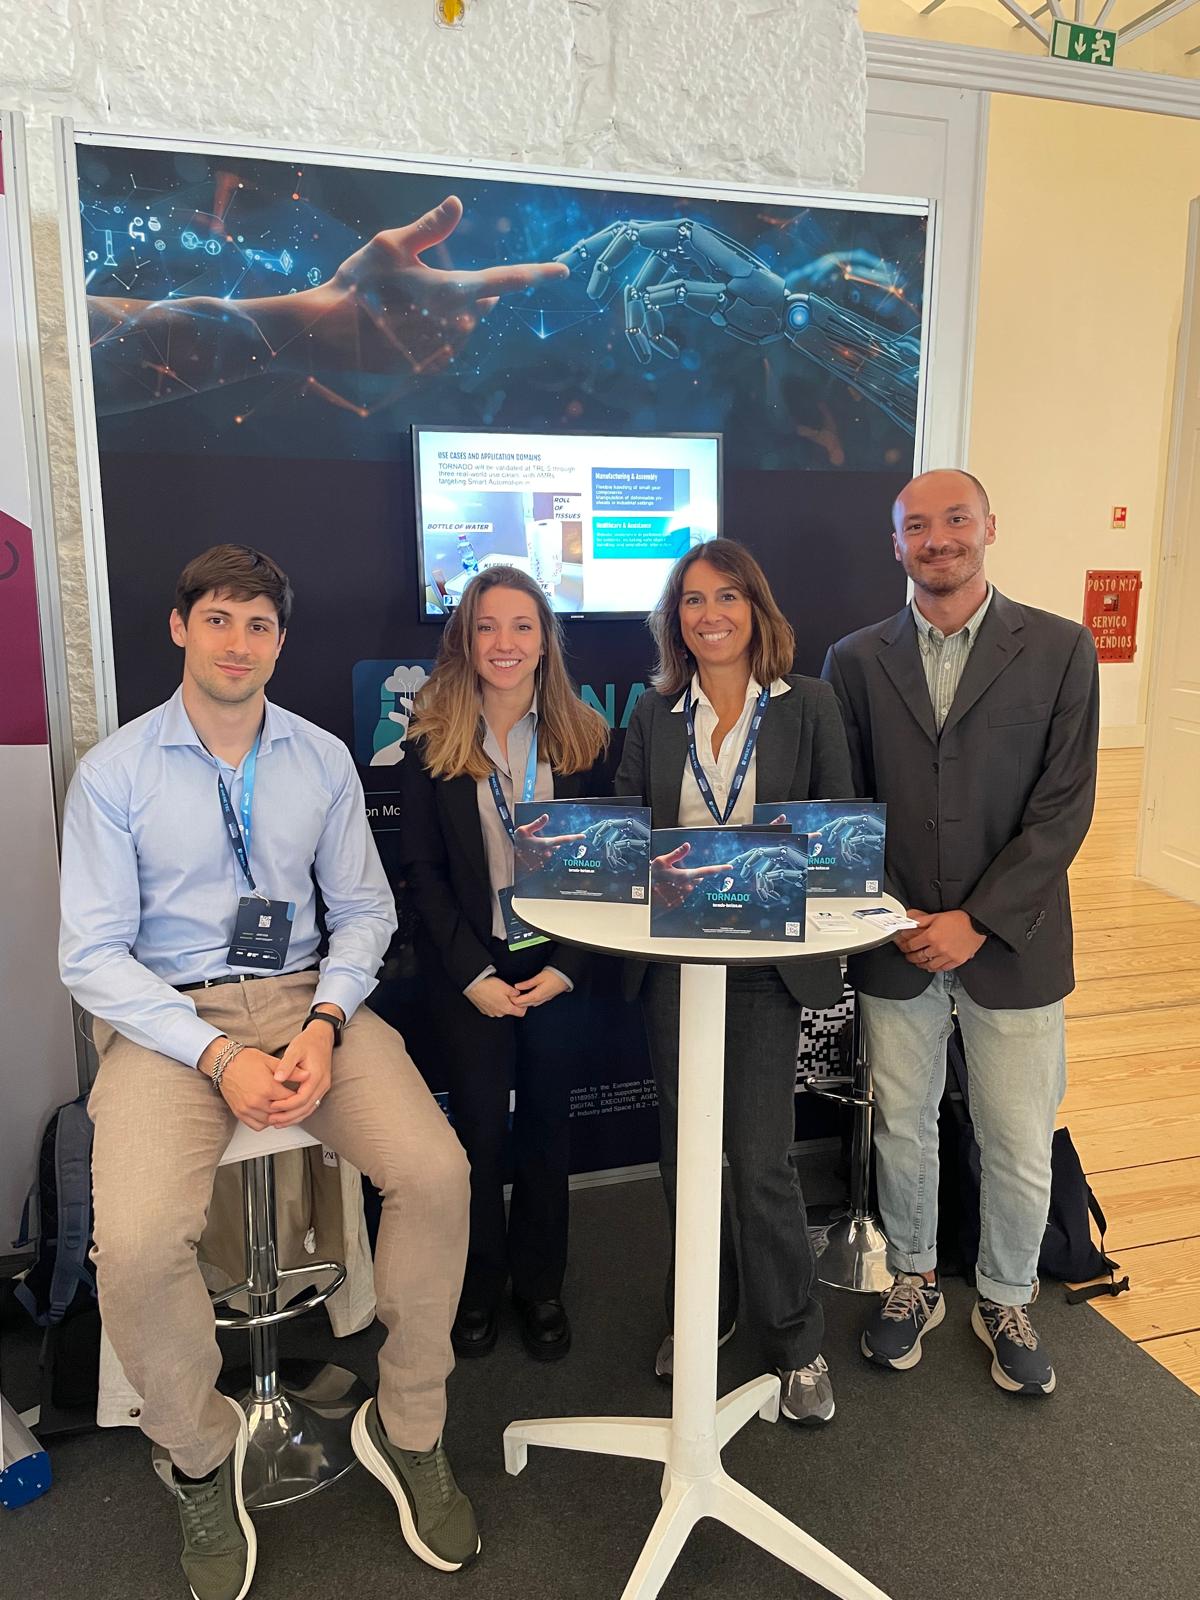
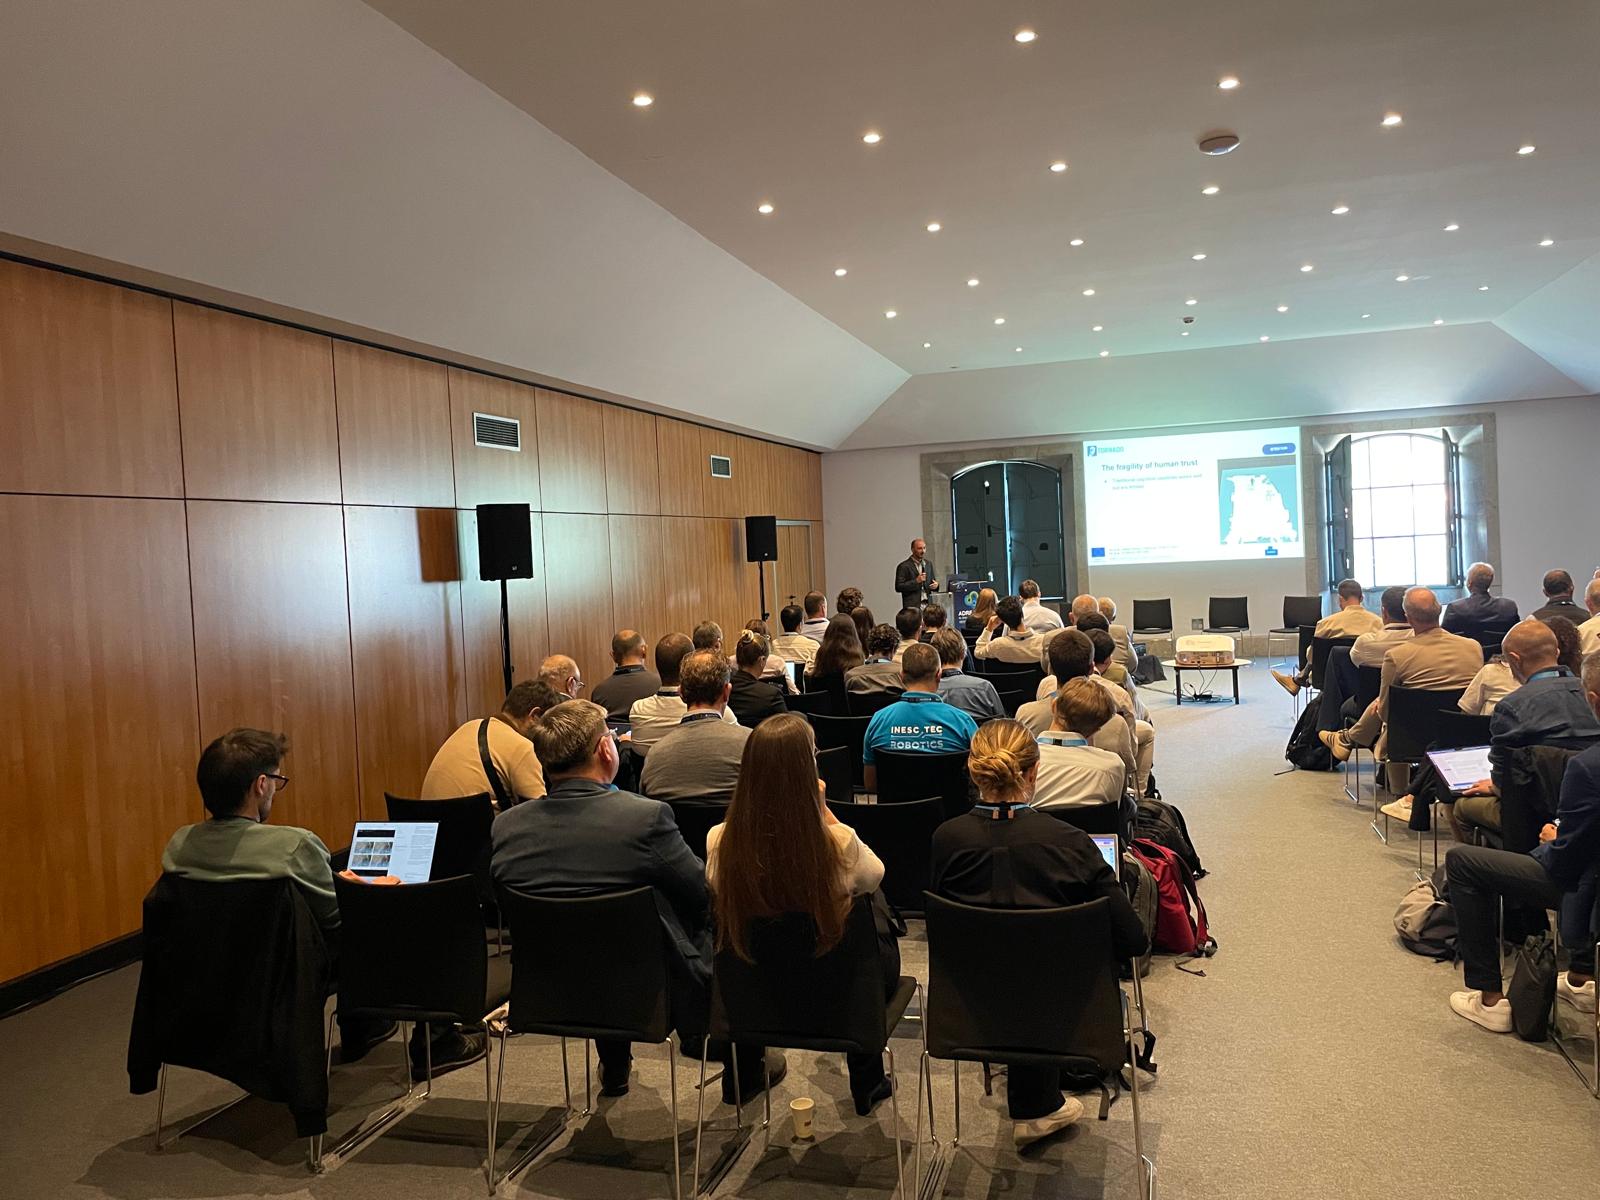
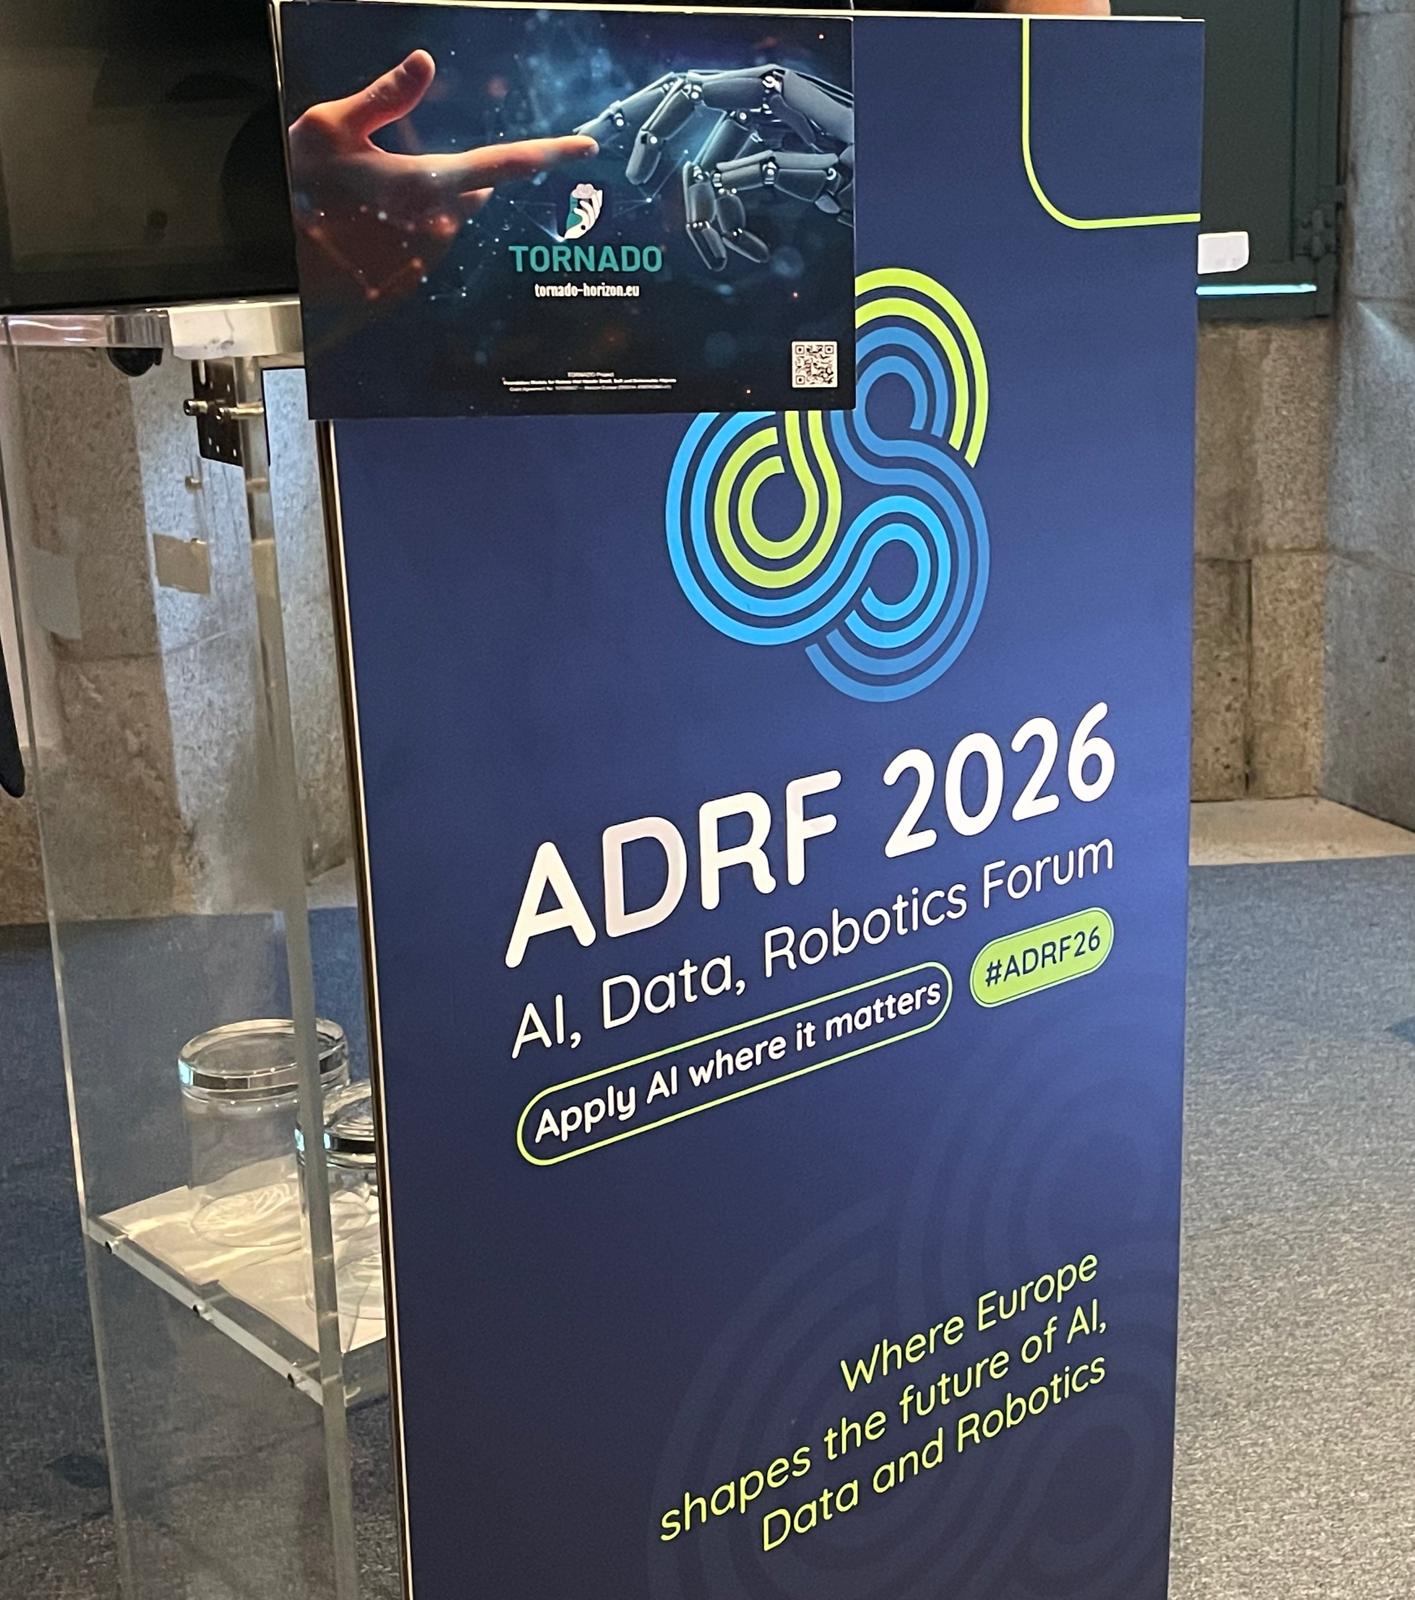
The Horizon Europe project TORNADO (foundaTion mOdels for Robots that haNdle smAll, soft and Deformable Objects) presented its latest research results at the AI, Data and Robotics Forum 2026 (ADRF26), held in Porto, Portugal.
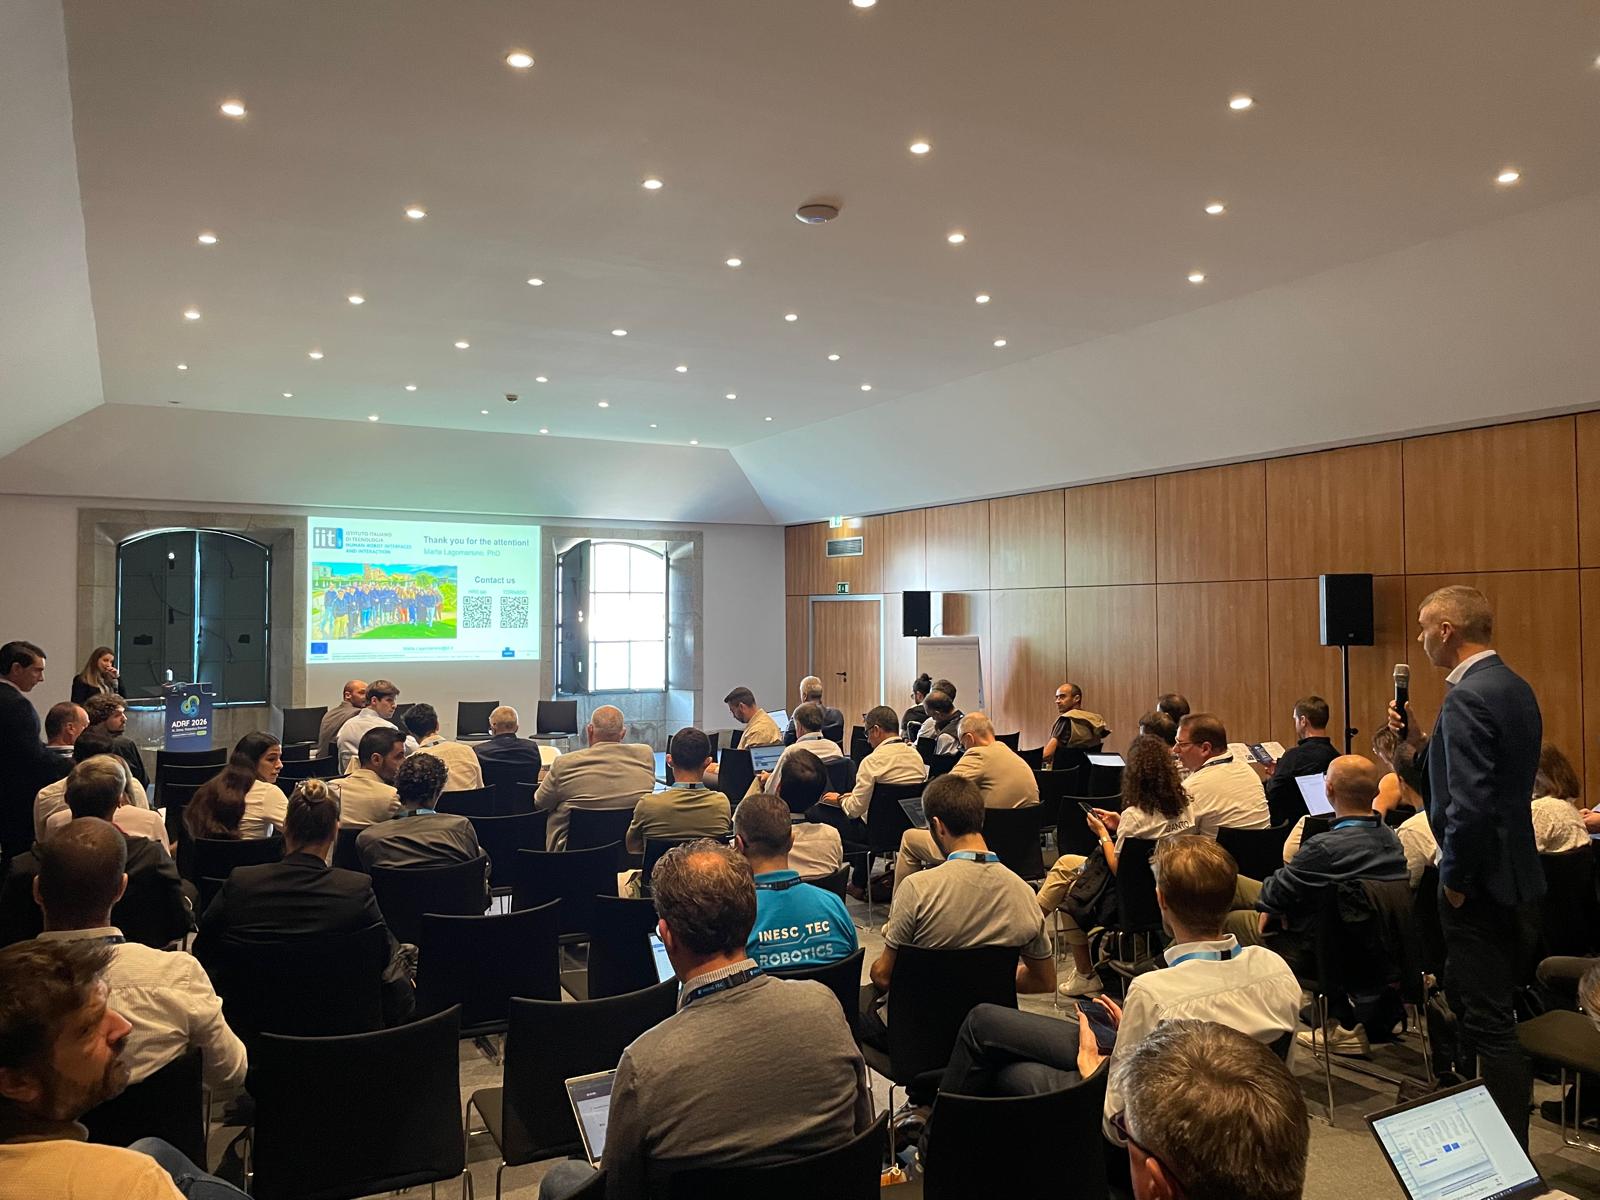
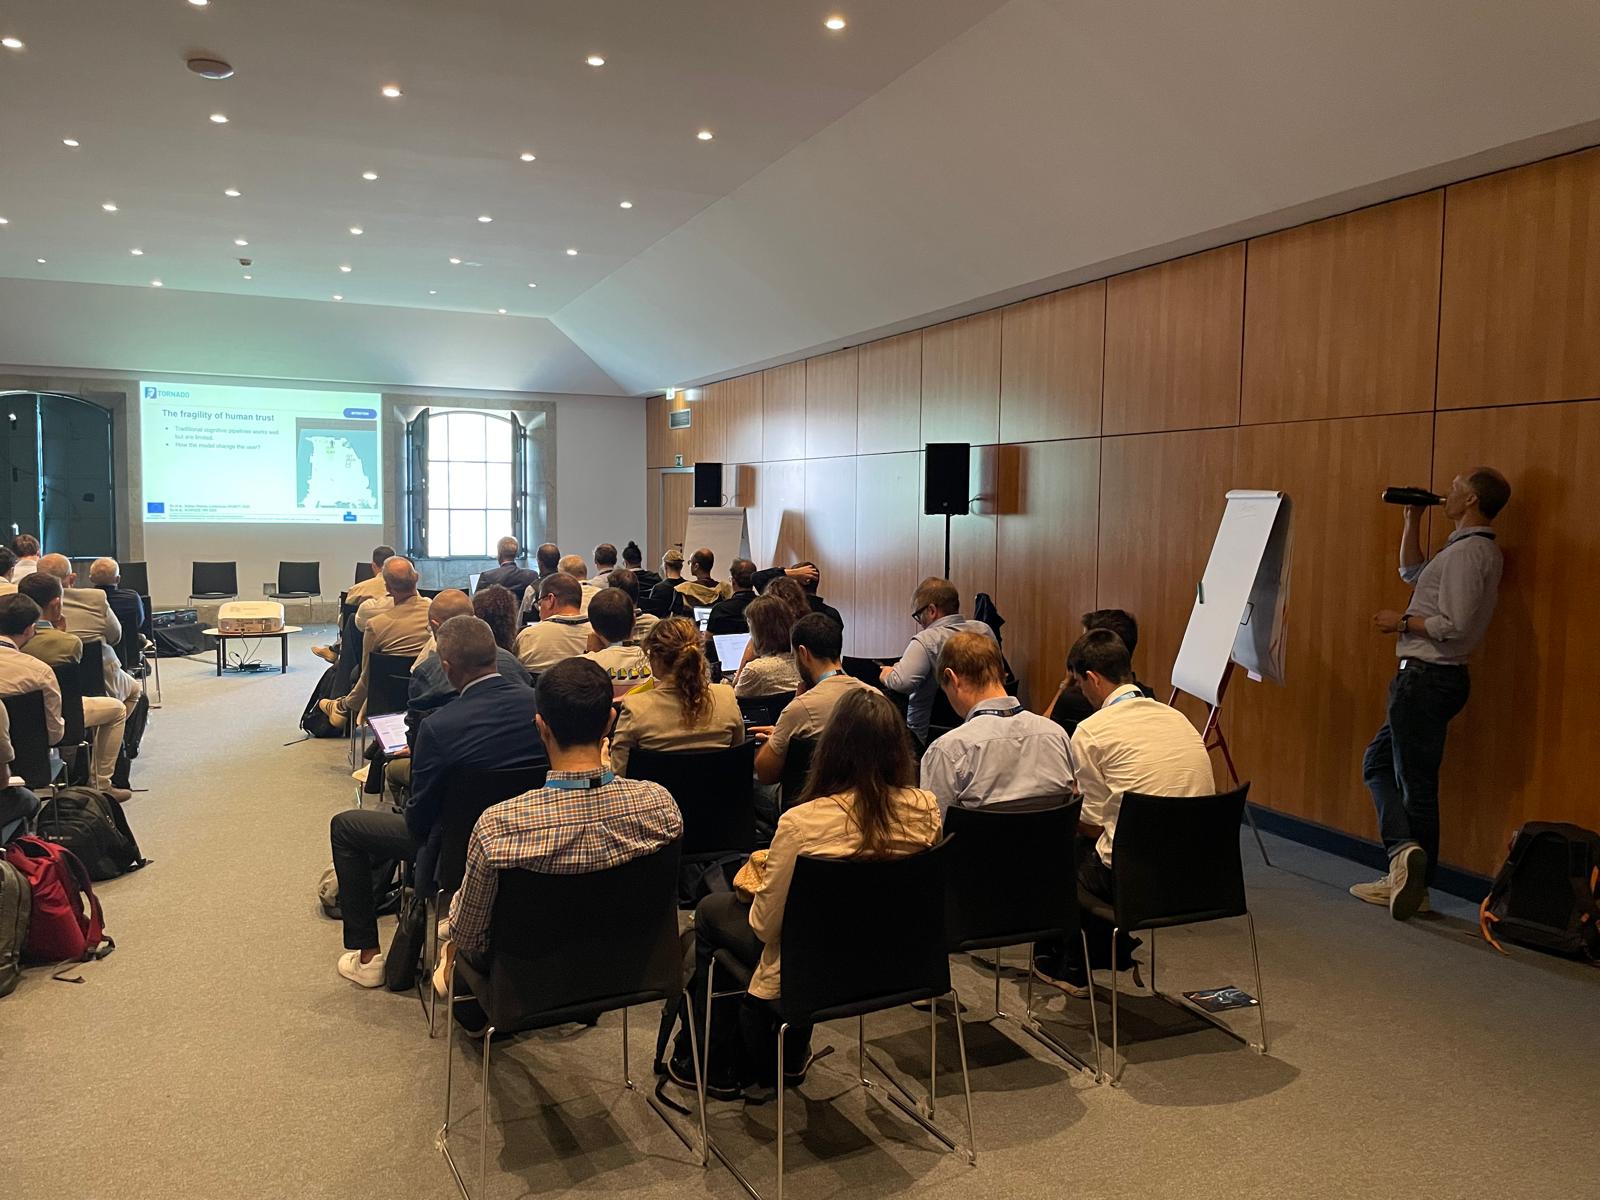
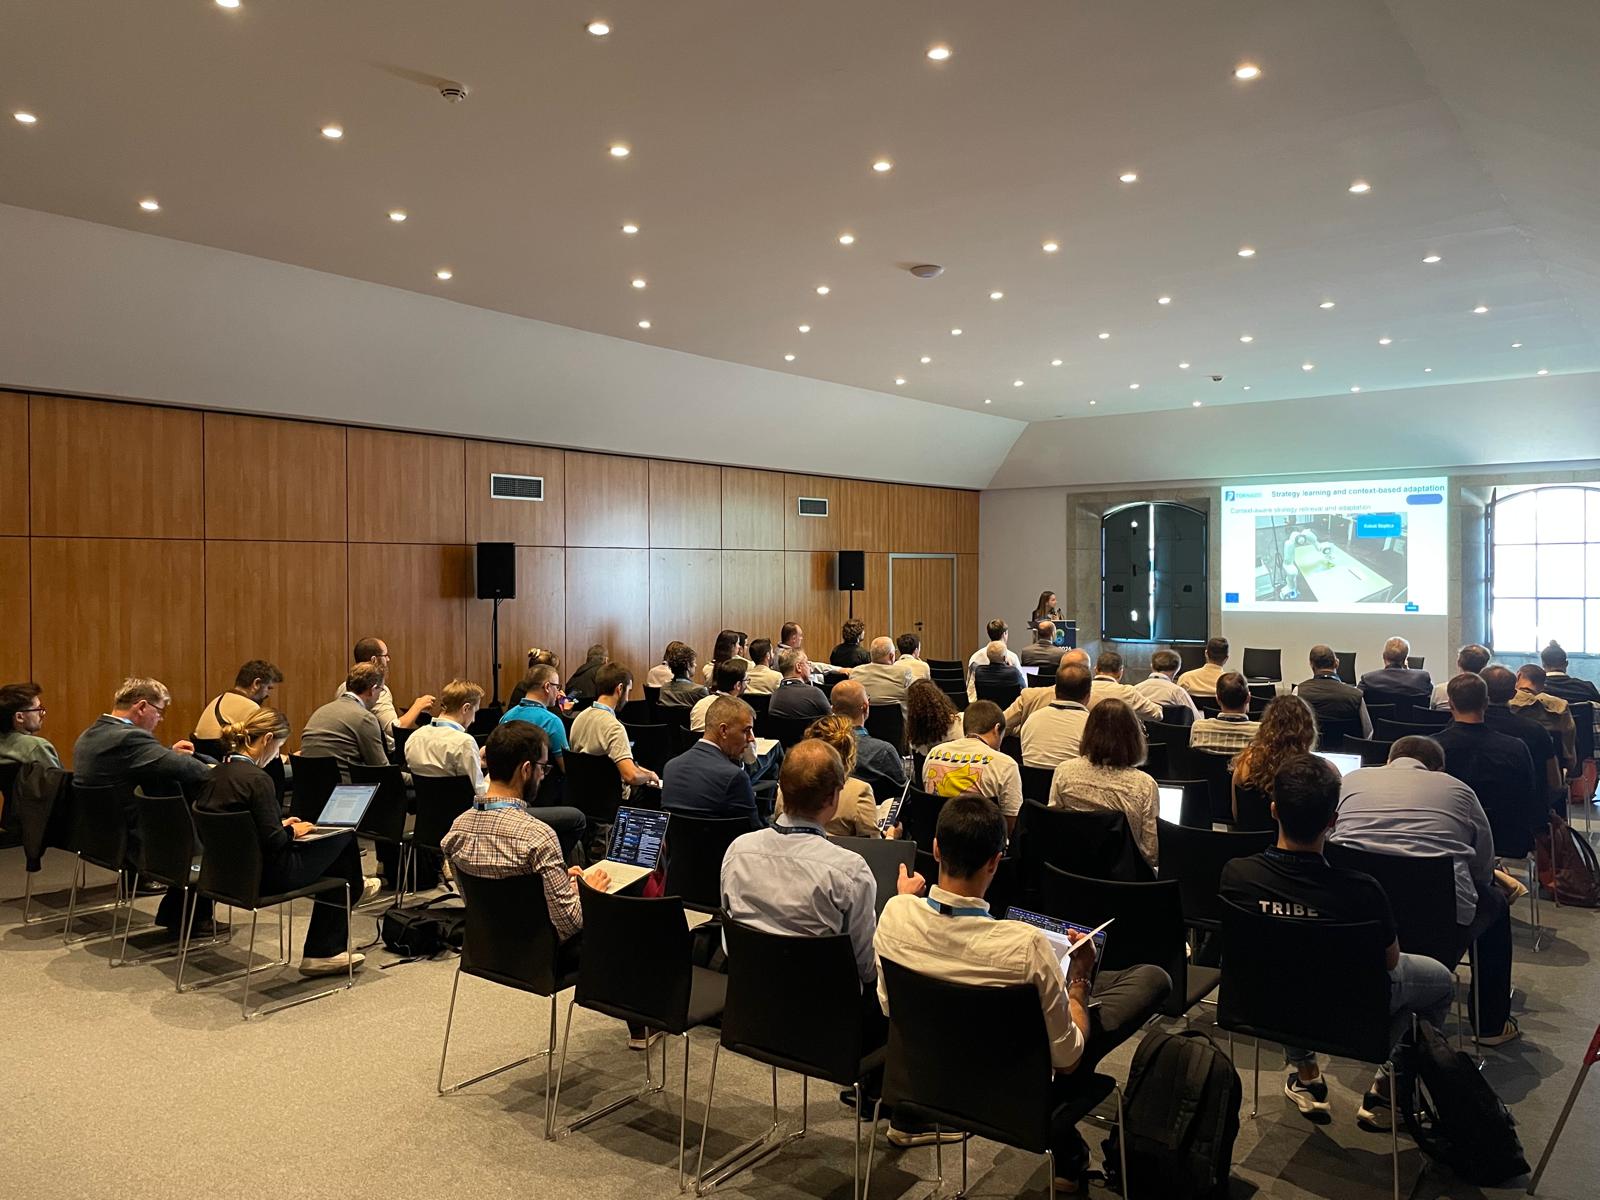
On 14 October 2026, the project organised the workshop “When Robots Learn to Interact: Foundation Models for Human-Robot Collaboration and Dexterous Manipulation in Healthcare and Industry” at the Alfândega do Porto Congress Centre.
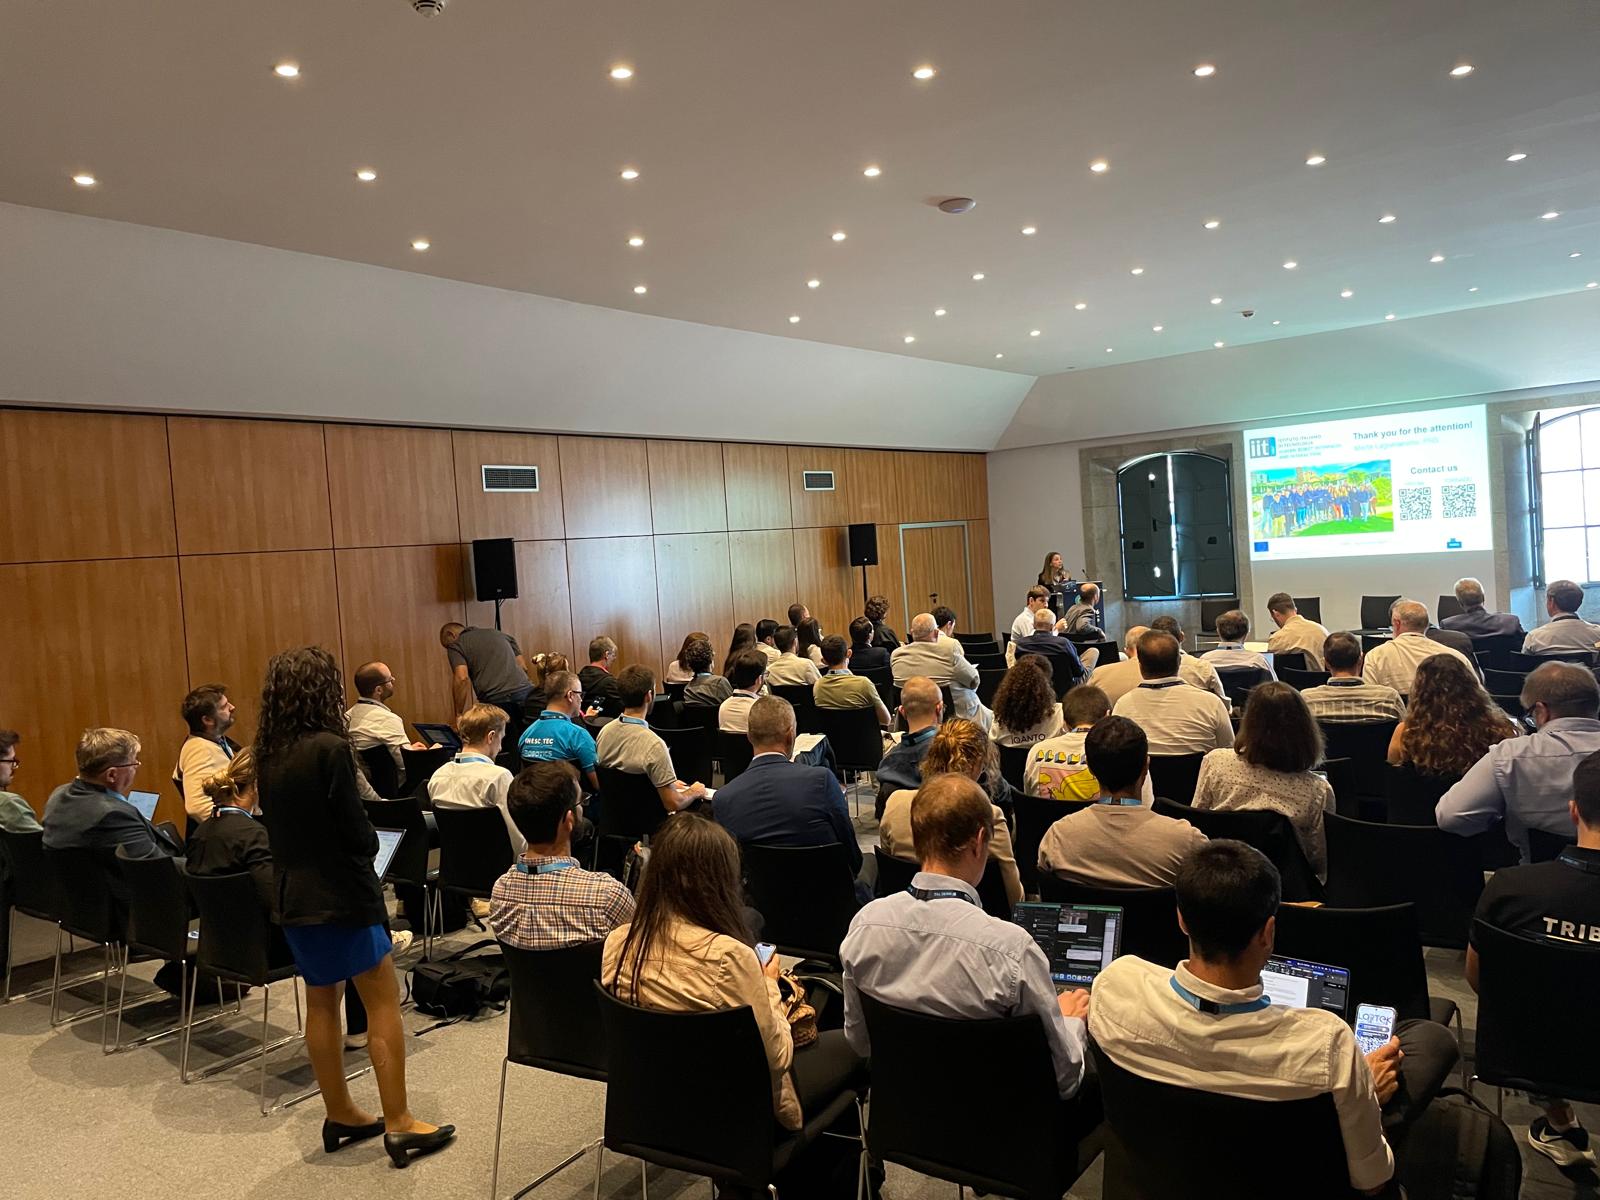
The workshop brought together researchers, industry representatives and stakeholders to discuss recent advances in AI-powered robotics and the challenges of deploying intelligent robotic systems in real-world environments.
KEY RESEARCH HIGHLIGHTS
Manipulation of Deformable Objects
-
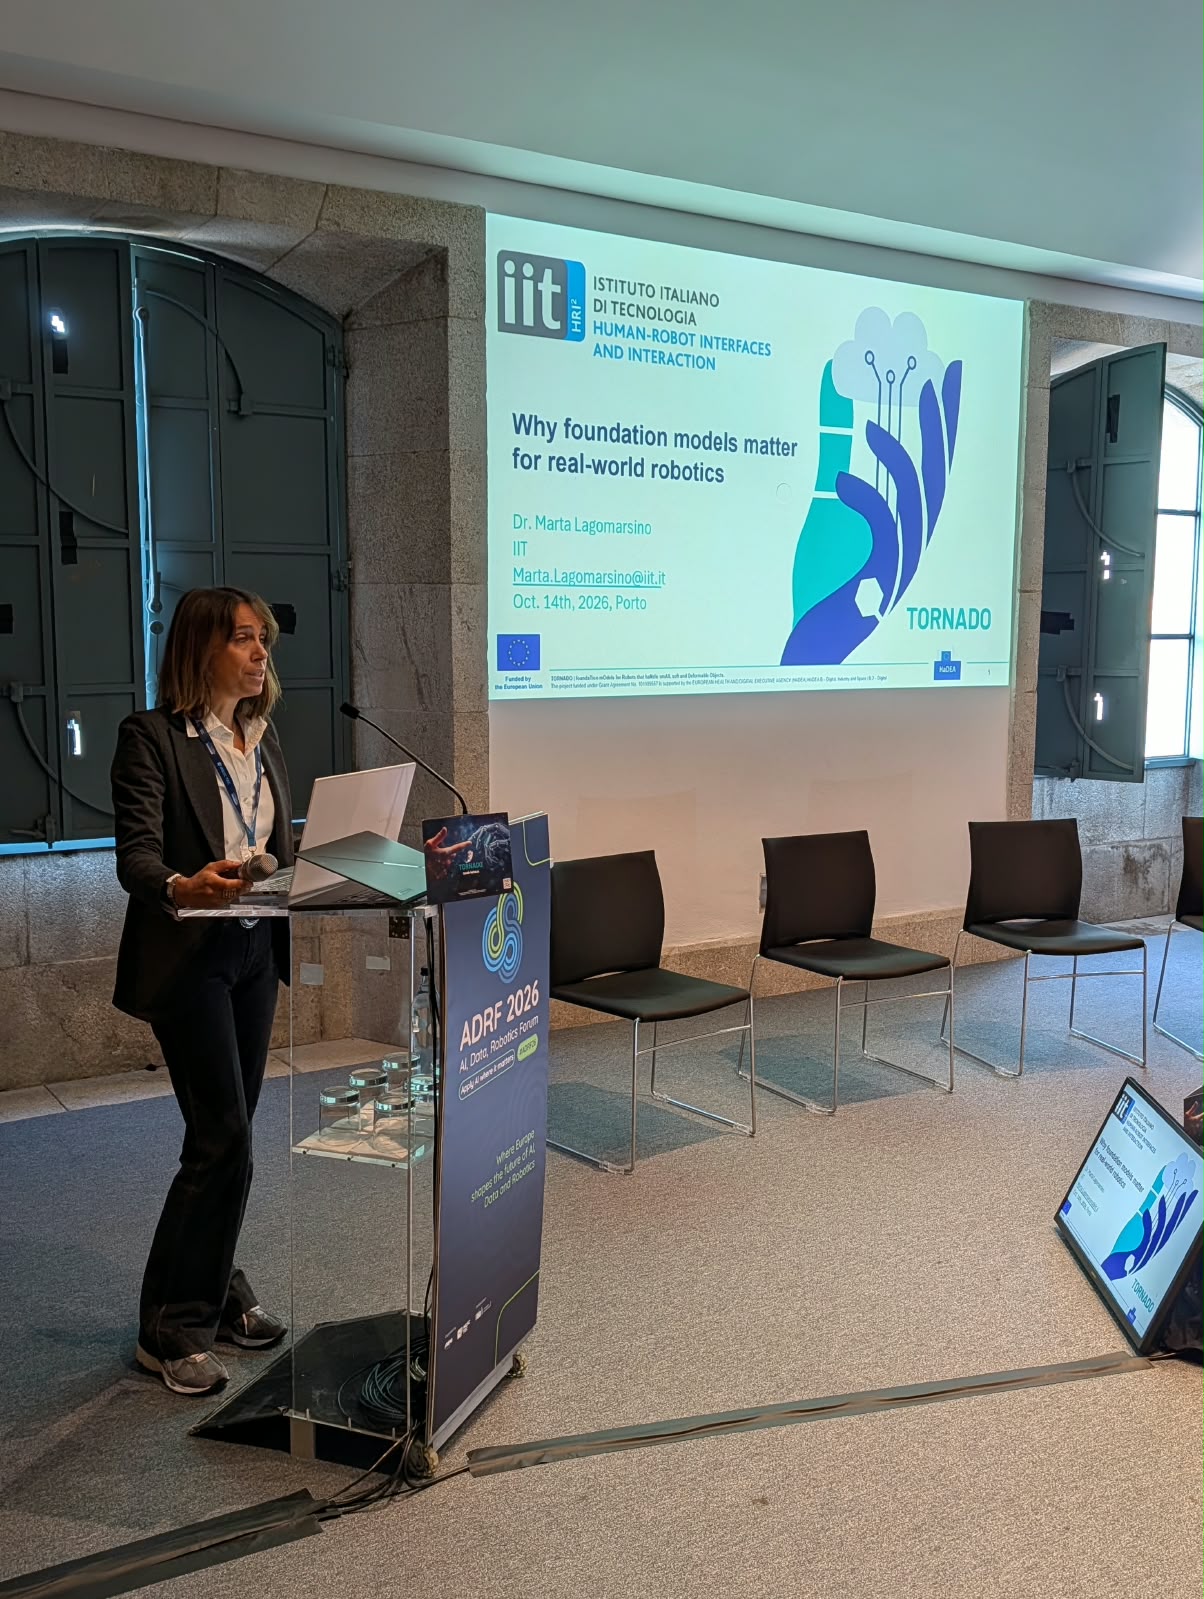
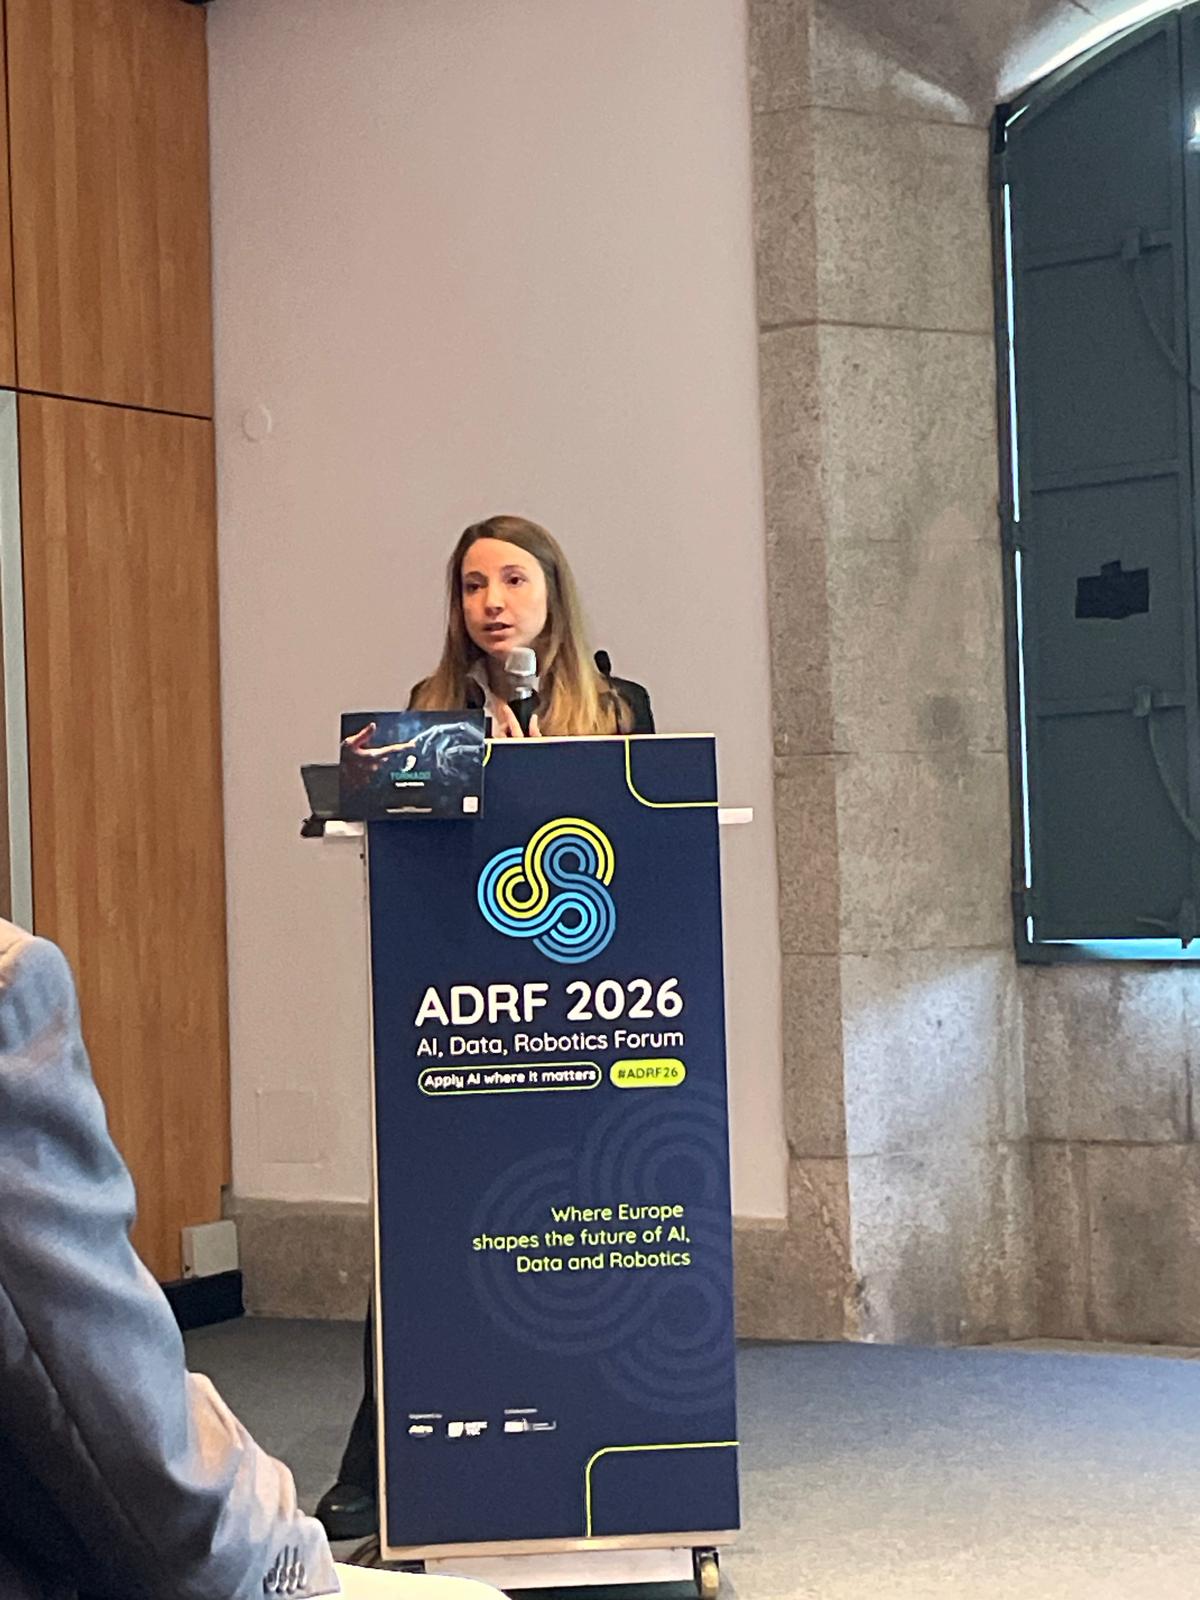
Marta Lagomarsino from the Istituto Italiano di Tecnologia (IIT) presented advances in robotic manipulation of deformable materials, including fabrics, cables and small tubes. The research explored how foundation models, simulation-based learning and human demonstrations can support more adaptable robotic manipulation.
Human–Robot Interaction and Intention Recognition
-
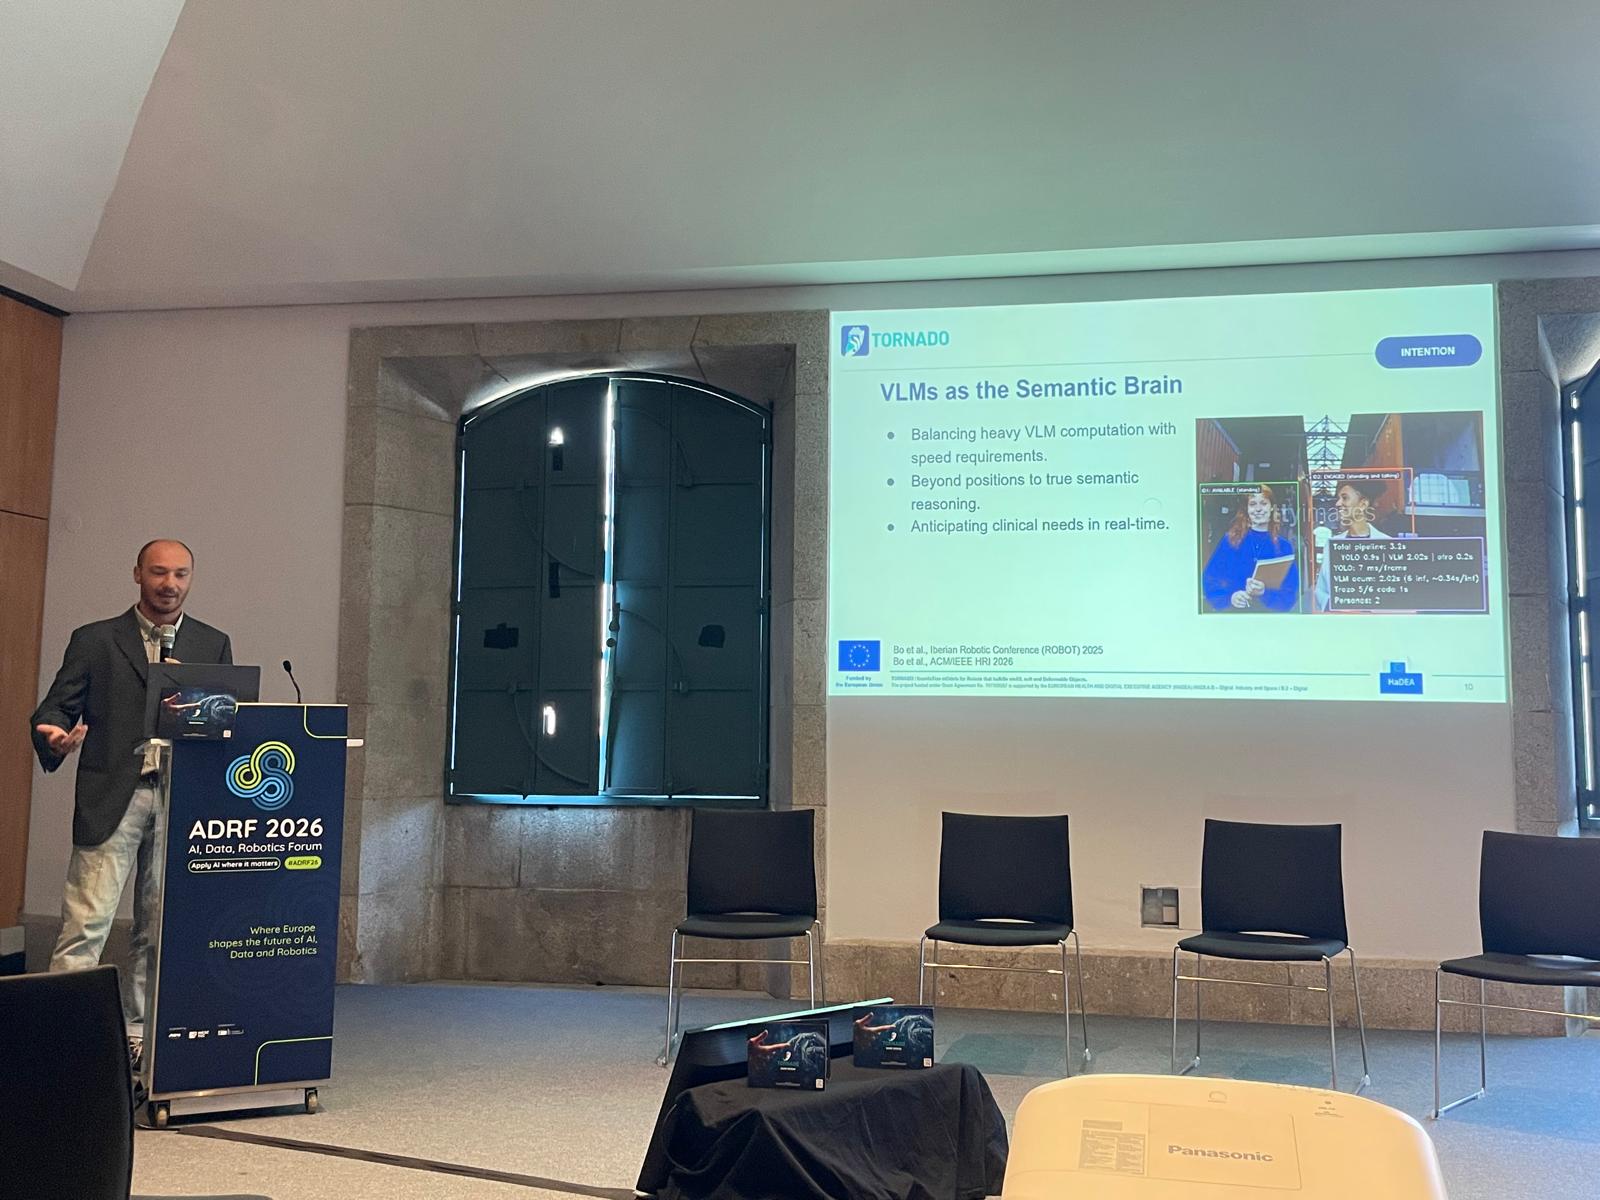
Valerio Bo from the Universitat Politècnica de Catalunya (UPC-IRI) presented research on human intention recognition, socially aware robot navigation and adaptive human–robot interaction. The work focused on enabling robots to better understand human behaviour, communicate their intentions and respond appropriately in shared environments.
From Research to Real-World Deployment
-
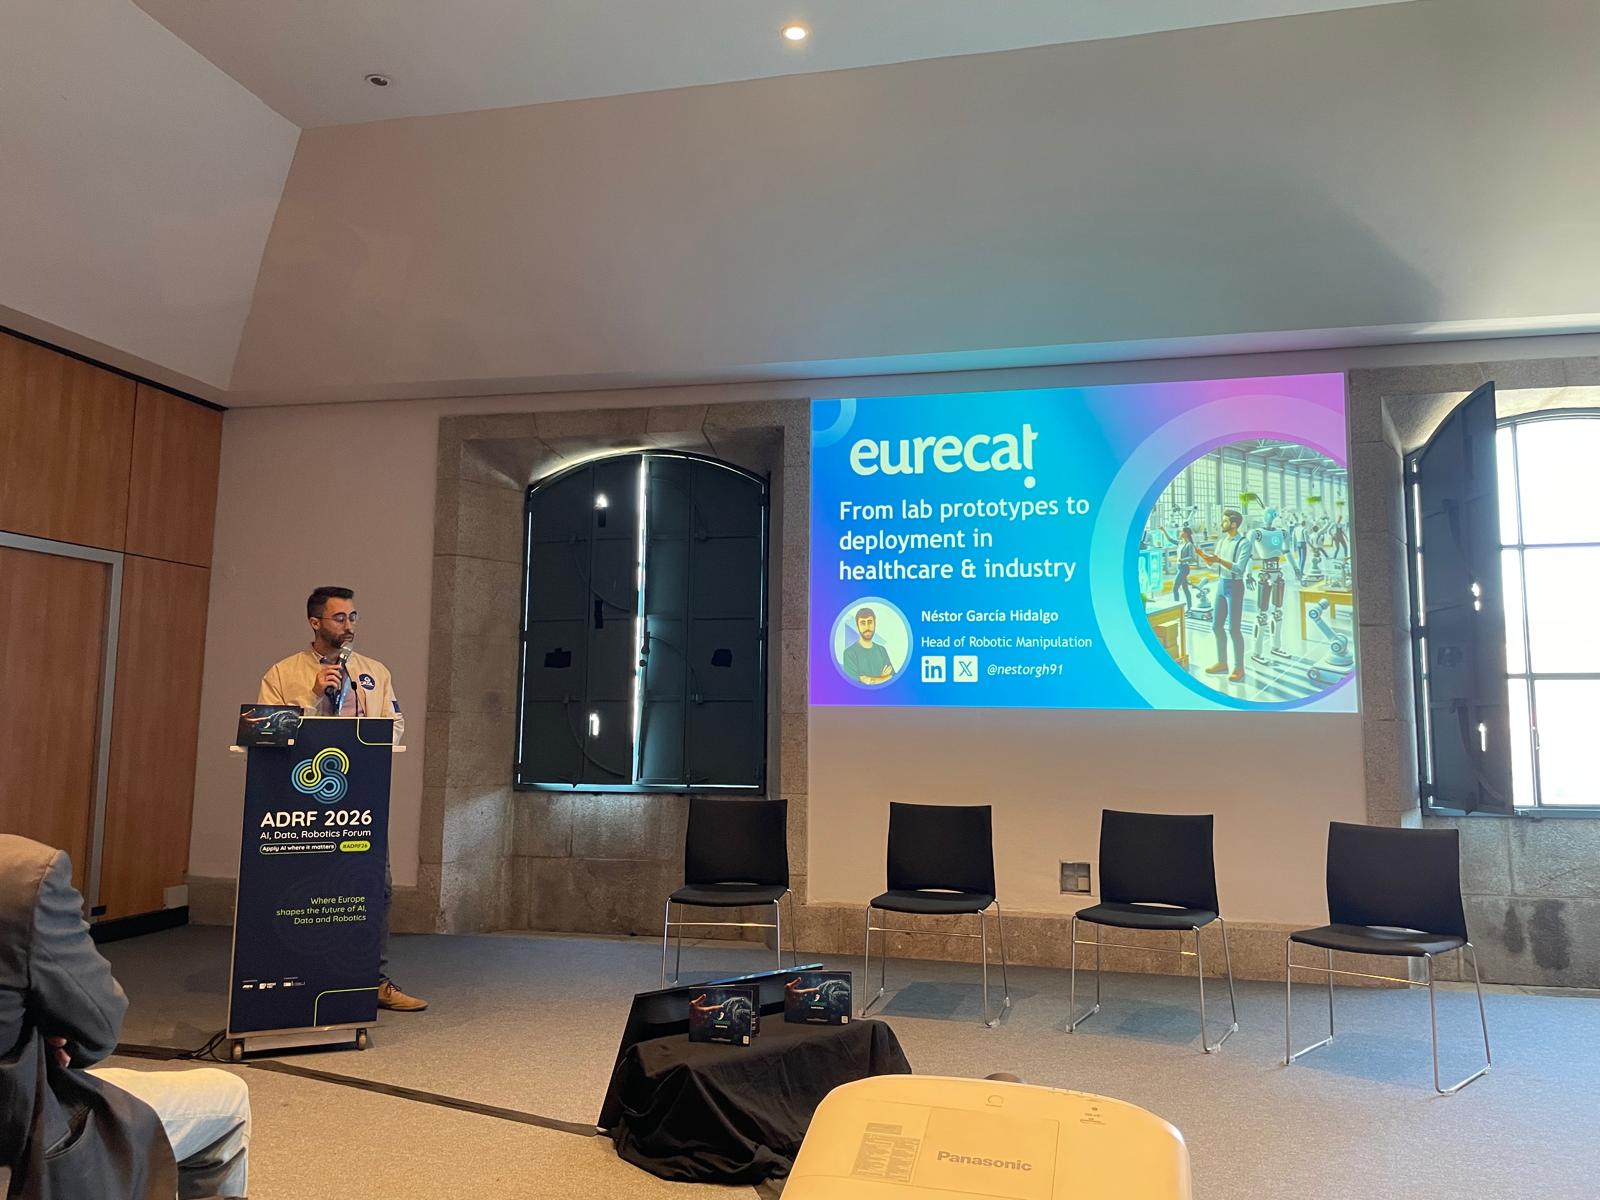
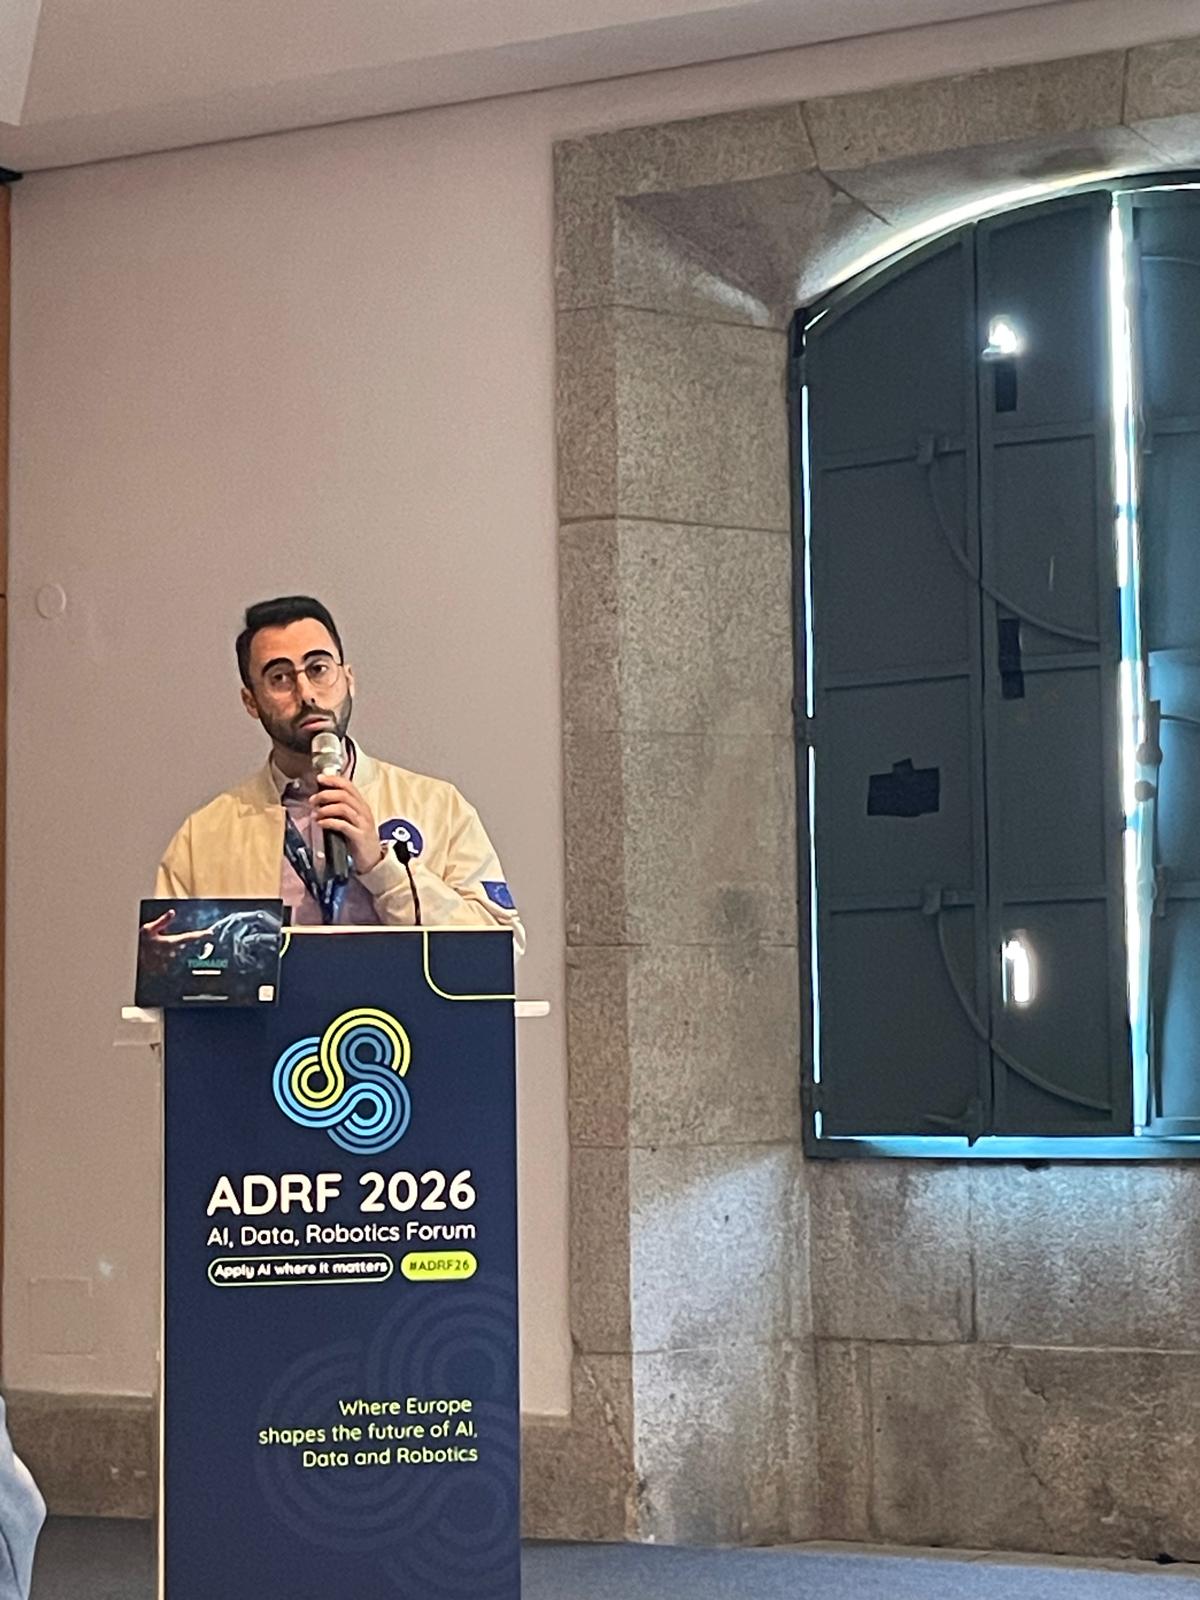
Néstor García Hidalgo from Eurecat discussed the challenges of transferring robotic technologies from laboratory demonstrations to practical applications in healthcare and industry, highlighting the importance of reliability, validation and integration into operational workflows.
INDUSTRY INTEREST AND NEXT STEPS
The workshop also encouraged discussions on access to the foundation models developed within TORNADO, data sovereignty and opportunities for future exploitation.
These insights will contribute to the project’s ongoing research, validation and exploitation activities, supporting the development of reliable and human-centred robotic systems.
-
PASIPHAE LAB AND HMU IN TORNADO
PASIPHAE Lab at the Hellenic Mediterranean University (HMU) participates in the TORNADO consortium, with HMU serving as a Task Leader in the project. The laboratory contributes to the project's development and integration activities, supporting the implementation of its cloud robotics platform and the interaction between robotic systems and AI-based services. Through its participation, PASIPHAE Lab supports TORNADO's objective of advancing adaptive and intelligent robotic technologies for real-world applications.
MORE INFORMATION
Read the official TORNADO article for further details about the workshop, the research presentations and the discussions in Porto:
Explore the TORNADO project website:
EU FUNDING ACKNOWLEDGEMENT
TORNADO is funded by the European Union under Grant Agreement No. 101189557. Views and opinions expressed are however those of the author(s) only and do not necessarily reflect those of the European Union or the European Health and Digital Executive Agency (HaDEA). Neither the European Union nor the granting authority can be held responsible for them.